




I build robot perception, control, and AI software—from humanoid simulation and physical arm teleoperation to retrieval tools that show their sources.
Seeking robotics software, embodied AI, computer vision, and AI/software engineering roles. M.S. Artificial Intelligence and B.S. Computer Science, Oregon State University.
Portfolio · Résumé · LinkedIn · Email
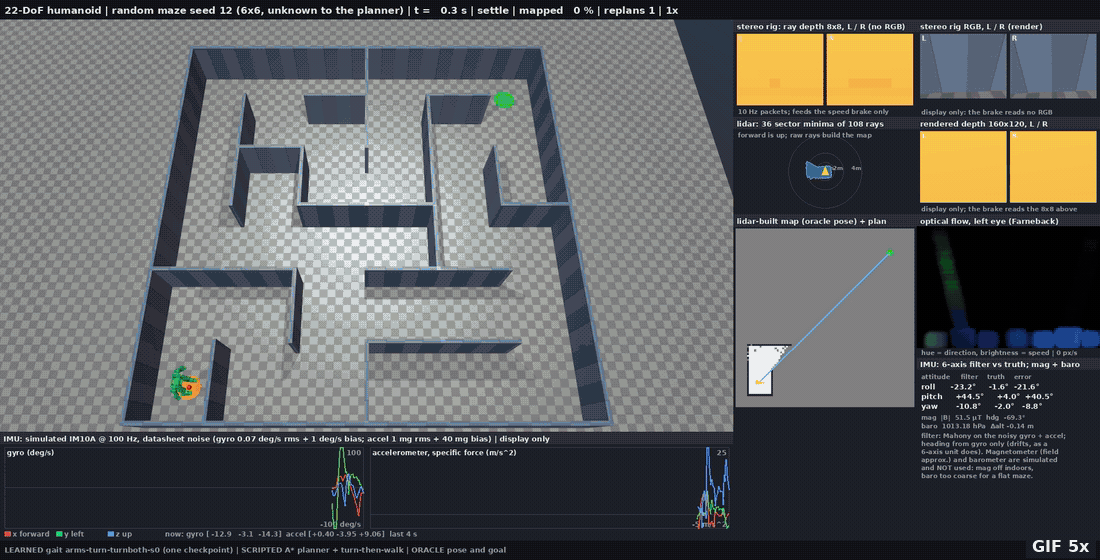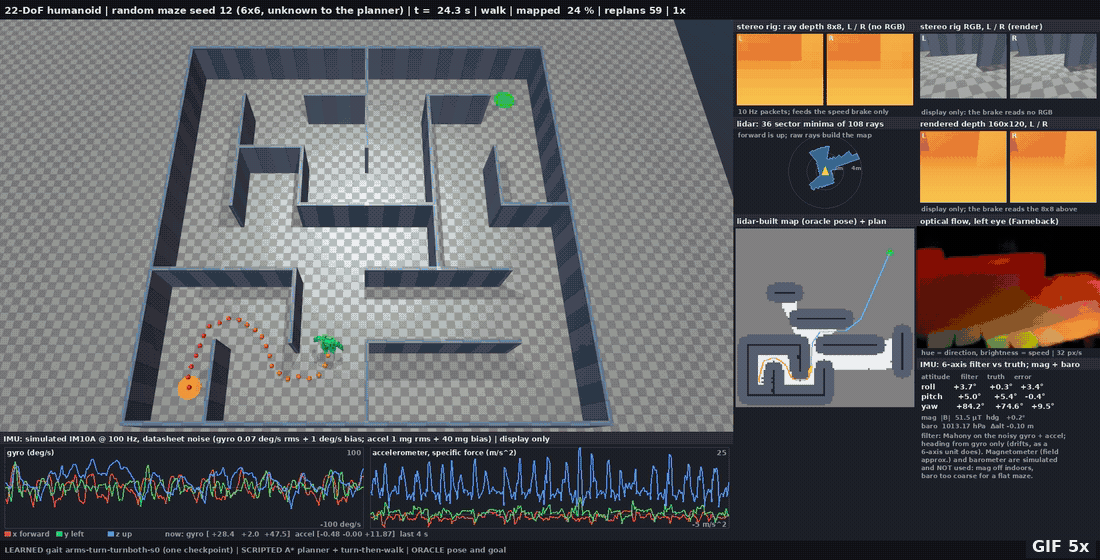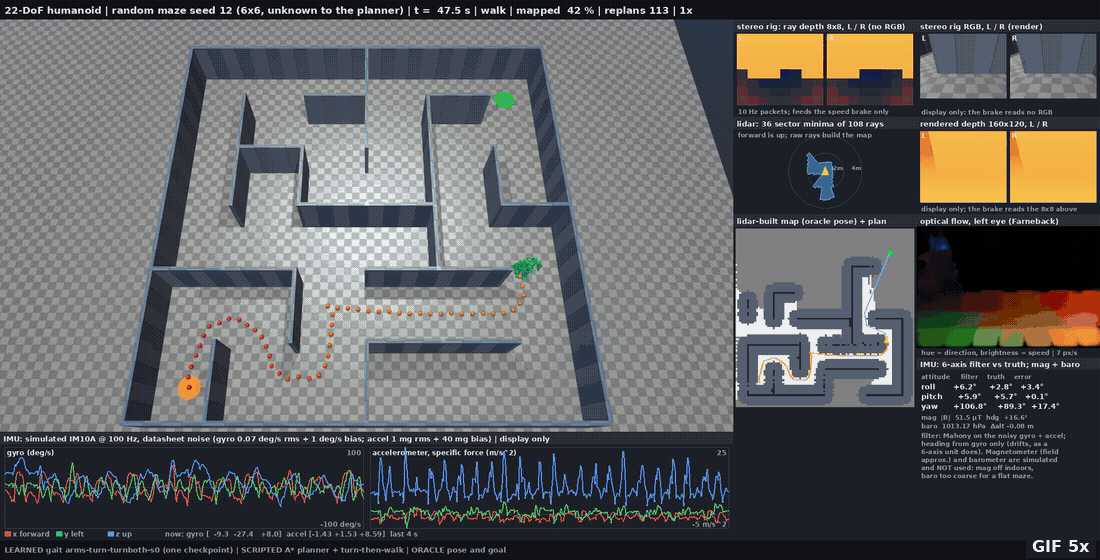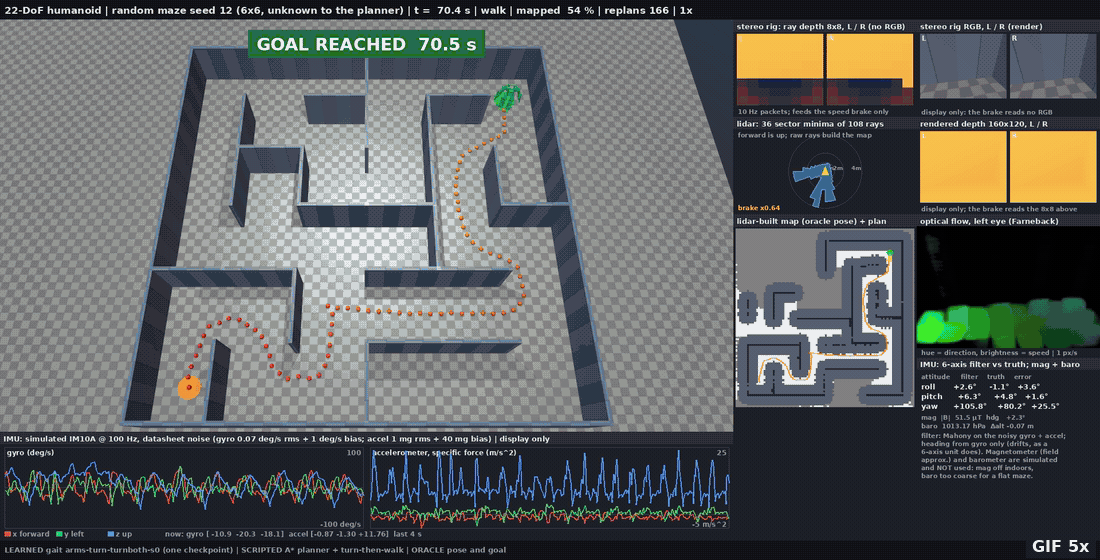
Learned gait with scripted planning and oracle pose/goal, at 5× playback. A selected simulation rollout; sensor display panels are separate from the control inputs.
Three areas in Humanoid Robustness Ladder:
- Locomotion & Control — Isaac Lab training, MuJoCo qualification, disturbances, and terrain rollouts. Recent turning and terrain studies retain their exact controller and evaluation scope.
- Perception & Navigation — Online lidar mapping, maze planning, sensor-fault studies, and matched navigation controls.
- Language-Guided Manipulation — SmolVLA selects a tumbler, loads a tray, and carries it to the instructed table. 76/100 held-out-phrasing successes in simulation, with standing assistance and a small instruction domain.
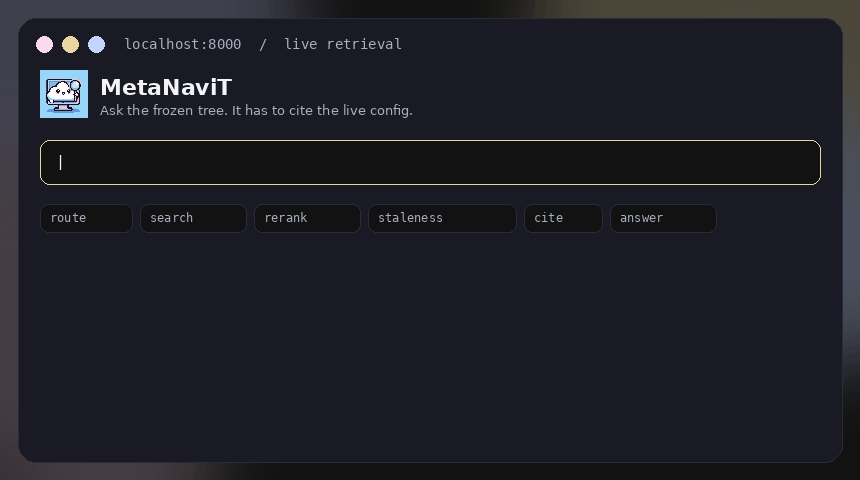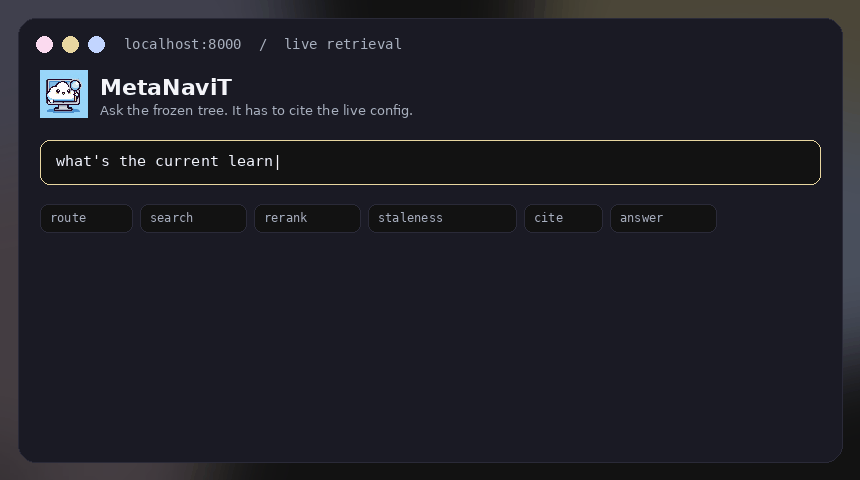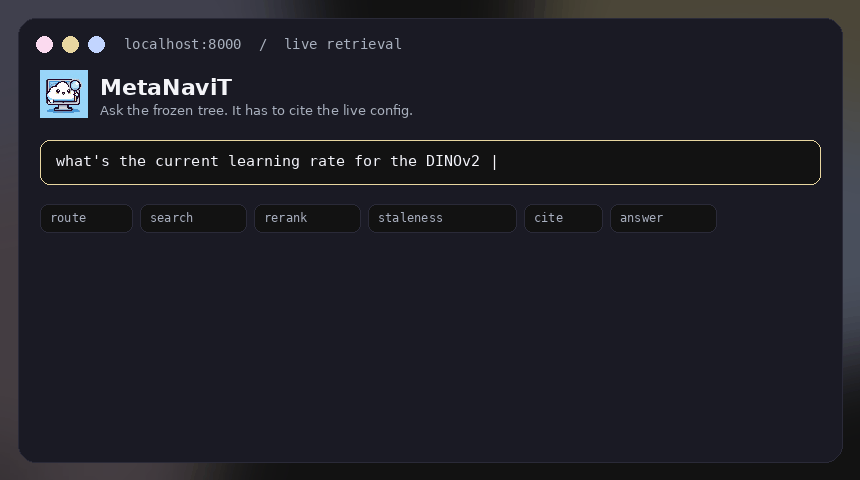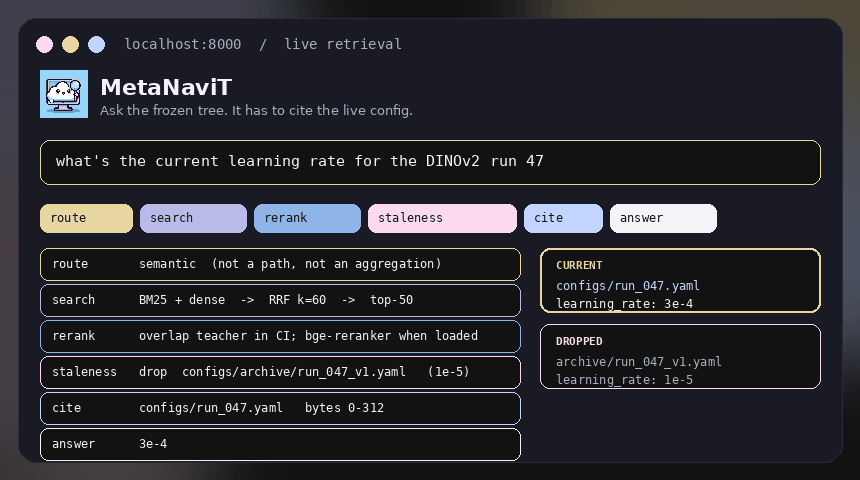
Illustrated retrieval workflow on demo files. Quantitative retrieval evaluations are documented separately.
- MetaNaviT — Hybrid retrieval over research files, source tracing, reviewable file operations, MCP tools, and ranking evaluations. Independent extensions build on an original six-person team project.
- Agentic Soccer MCP — FastAPI, LangGraph, and MCP tools for soccer analysis. Historical forecasting and agent tests are separate from the synthetic demo interface.
- Bimanual Garment Folding — Camera-driven policies, cloth simulation, and paired evaluation gates. Later runtime-horizon comparisons remain inconclusive; the baseline is retained.
- Vision-Guided Pruning — RGB-D branch tracking, sensor-gated release, and independent checks of recorded successes and failures in Isaac Sim.
- SPUR Metric Depth — PyTorch depth models, RGB-D branch perception, a FastAPI service, and ONNX export. Synthetic depth results are measured; real-orchard accuracy remains unverified.
Quest VR Teleoperation connects WebXR controller poses to inverse kinematics and SocketCAN arm control. Calibration checks cover ten arm joints. Watch the hardware preview.
Robotics & vision: Python, C++, PyTorch, OpenCV, Isaac Sim / Isaac Lab, MuJoCo, ROS 2, SocketCAN, ONNX Runtime.
AI & software: FastAPI, PostgreSQL / pgvector, hybrid retrieval, RAG, MCP, Docker, and Slurm.
The portfolio presents short visual case studies. The repositories contain setup, architecture, dated results, and current limits.