Variation Automation and Scalable Testing for Robotic Systems.
Robot software that passes one demo has not been tested. RoboVAST takes your robotics stack — a Nav2 navigation setup, a manipulation pipeline, whatever drives your robot — and runs it through hundreds of simulated runs that differ in the ways that matter: floorplans, start and goal poses, obstacles, sensor noise, the parameters of the stack itself. Every run is recorded with its provenance, every campaign lands in a queryable index, and the results come back as tables, plots and a web view of each run rather than a directory of bags.
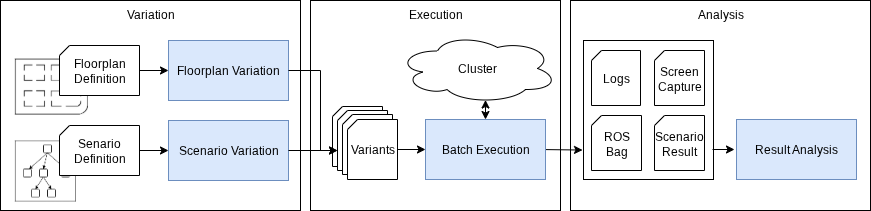
- Say what to vary, not how. A campaign is one file: which scenario, which factors, how many levels, how many repetitions. RoboVAST does the expansion, the scheduling and the bookkeeping.
- One campaign, any cluster. The same file runs as jobs on a one-node cluster on your laptop or across a Kubernetes cluster. Nothing about the campaign changes; only where it runs and how fast it finishes.
- Reproducible by construction. Pinned container images, recorded seeds and configuration, a run's full provenance beside its data. A result can be traced, and a campaign re-run.
- A simulator by name.
backend: roqsimgives you roqsim, a MuJoCo simulator for mobile robots, arms and mobile manipulators. Another simulator is another package. - Results you can ask questions of. Campaign data goes into a database; explore it in the web UI, in a notebook, or through an AI agent that can author, launch and analyse campaigns through the same interface you use.
- Built on scenario-execution for the single run and the Floorplan-DSL for generated indoor environments. Mobile robot navigation is the reference use case, with a ready-made set of environments and scenarios to start from.
pip install robovast-client              # drive a RoboVAST service someone runs for you
pip install "robovast[nav,roqsim]"       # the core: configuration, results, the MCP server
pip install robovast-cluster             # deploy and run the service on a Kubernetes cluster
Then vast cluster setup deploys the service — into minikube on your own machine, or a
cluster for a team — and vast workspace run launches a campaign.
Documentation, from the quickstart to writing your own variation type or simulator backend: cps-test-lab.github.io/robovast.
Apache-2.0.