Repository navigation
Teleop Bar Retrieval
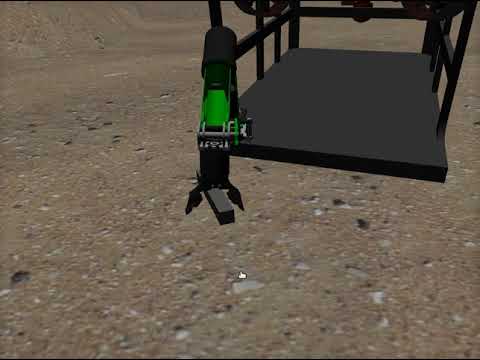
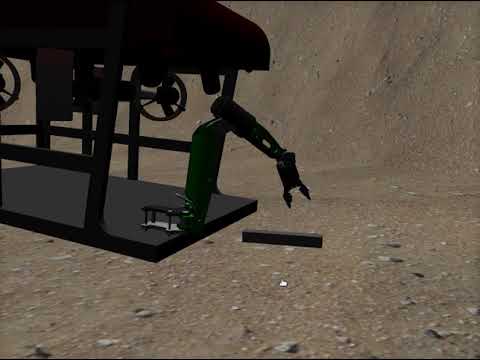
After successful installation, users will launch an underwater environment containing a RexROV vehicle with a mounted Oberon 7 arm. A rectangular bar is located on the seafloor of the environment.
roslaunch dave_demo_launch dave_demo.launch
The vehicle can be teleoperated using a Gamepad.
You will need a joystick to perform the actual mission. The Logitech F310 Gamepad Mapping provides key mappings for maneuvering the vehicle and arm. See this page.
Below are a few videos that demonstrate teleoperation of the vehicle and arm to successfully grasp the rectangular bar.